Sep 07, 2026
Swiss Innovation Challenge Pitch 2
We made it through to the final round. 🚀 Out of …
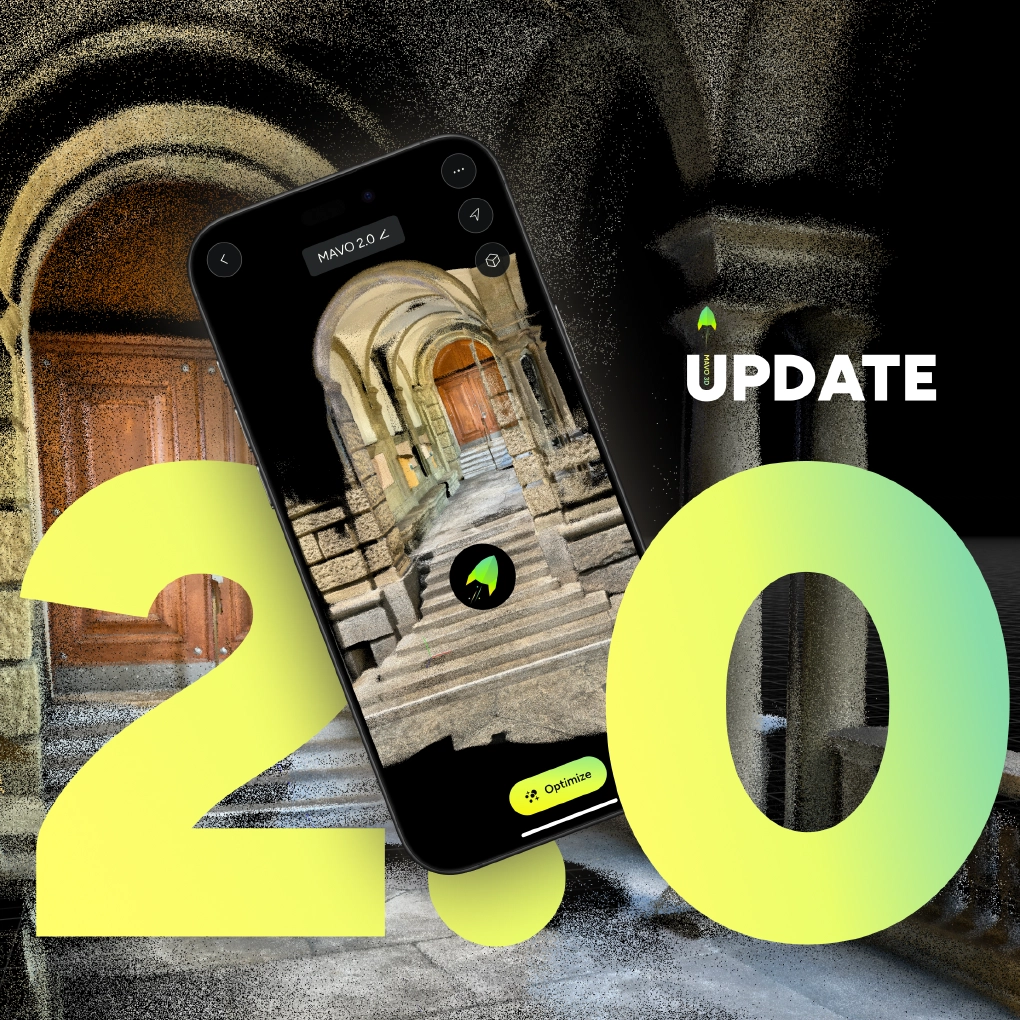
Smarter optimization for more accurate 3D point clouds.
MAVO 3D v2.0 introduces a redesigned optimization engine for more accurate and reliable 3D point clouds for professional 3D building documentation. Over the last months we tested it across a wide range of real-world scenarios. Now the pipeline provides more reliable drift detection and correction, more robust handling of rotational movement, more stable processing of large indoor scans, and improved final point cloud registration.
Version 2.0 is a major update to MAVO 3D and the best thing is that you won’t notice a change in your workflow.
Fortunately (or unfortunately for us, since most of the improvements happen under the hood) the 3D scanning process is the same as in version 1.0 Walk around the site, point your iPhone Pro or iPad Pro to the structures you want to capture in 3D and do one or multiple loop closures to provide enough overlap for later 3D reconstruction.
Just like previously, post-scanning optimization requires RAW data to be enabled during capture.
After scanning you can let MAVO 3D optimize the scan file and this is where the new pipeline kicks in. -> Open the scan in the viewer, tap the optimization button, and wait a little while MAVO processes the data.
If you’ve tested the app before and ran into reconstruction issues, especially in complex indoor environments, this version is worth another look.
You can run the optimization again on existing scan projects, the original raw scan data won’t be affected.
Version 2.0 is our first launch on Product Hunt, check it out:
All releases here: Release Notes.
Wanna stay updated about our progresss? Subscribe for our newsletter: